 Grade 11
 Sloviansk, Donetska Oblast
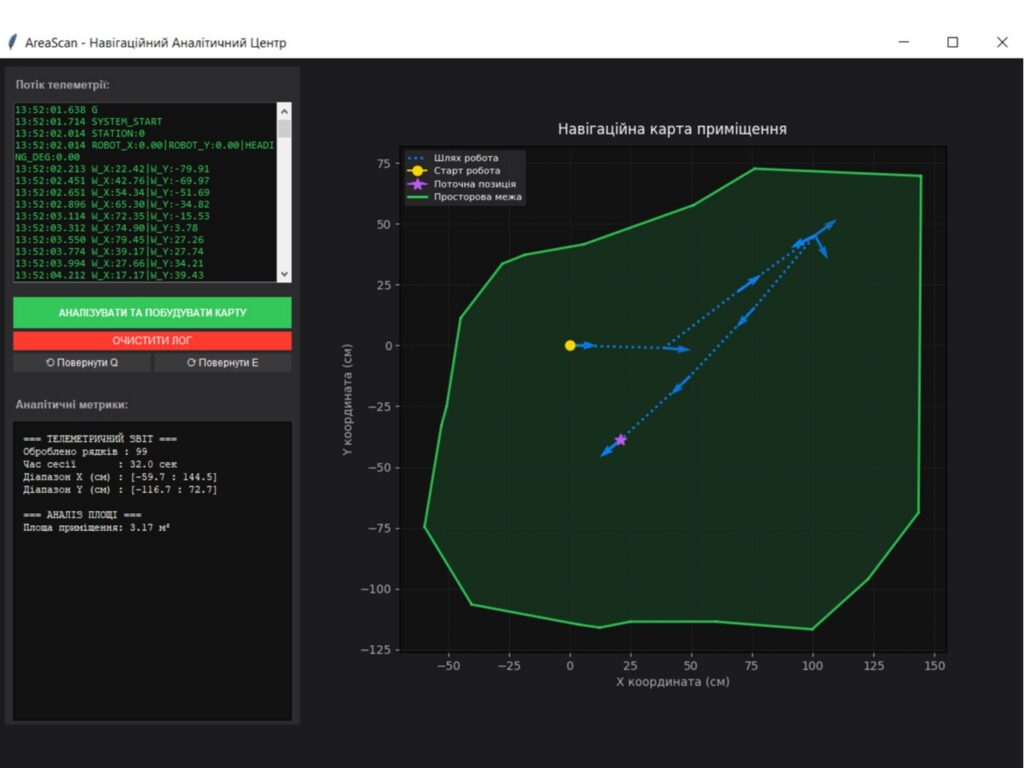
Distributed Dual-MCU Architecture and UART Interface Matching
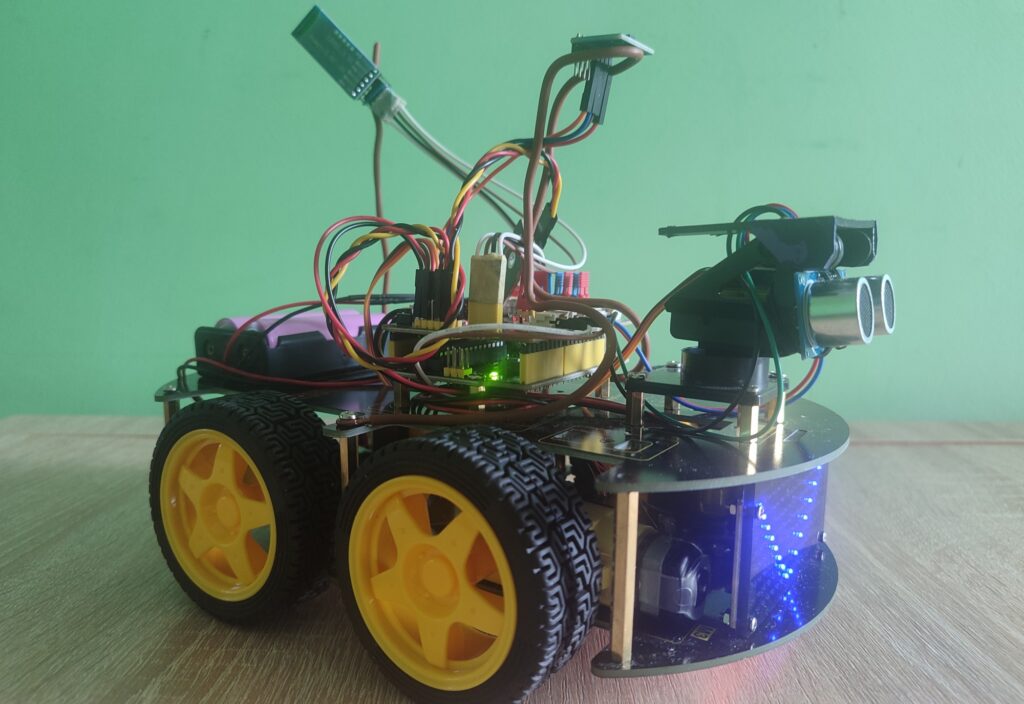
To offload the computational core and achieve maximum operational stability, I split the system control between two microcontrollers:
- Keyestudio Uno (ATmega328P): handles low-level control of the mechanics, power section, and kinematics of the 4WD chassis motors.
- ESP32: responsible for processing
Sign in to join the conversation.
Anyone can like; writing a comment takes a UKRIC account.
Sign in

0 comments.
Sign in to join the conversation.